Free resources
Practical guides on robotics, written by experts.
Whitepapers
Ebooks written by our engineers
A collection of whitepapers on robotics, written by our engineers and available for free download.
We build the simulation environments your team needs to test software at scale, reduce hardware dependency, and ship with more confidence.
Schedule a callHigh-fidelity simulation pipelines built for the next generation of robotics. We provide the infrastructure to train advanced AI models, generate synthetic training data, and validate controller logic before your robots ever touch the physical world.
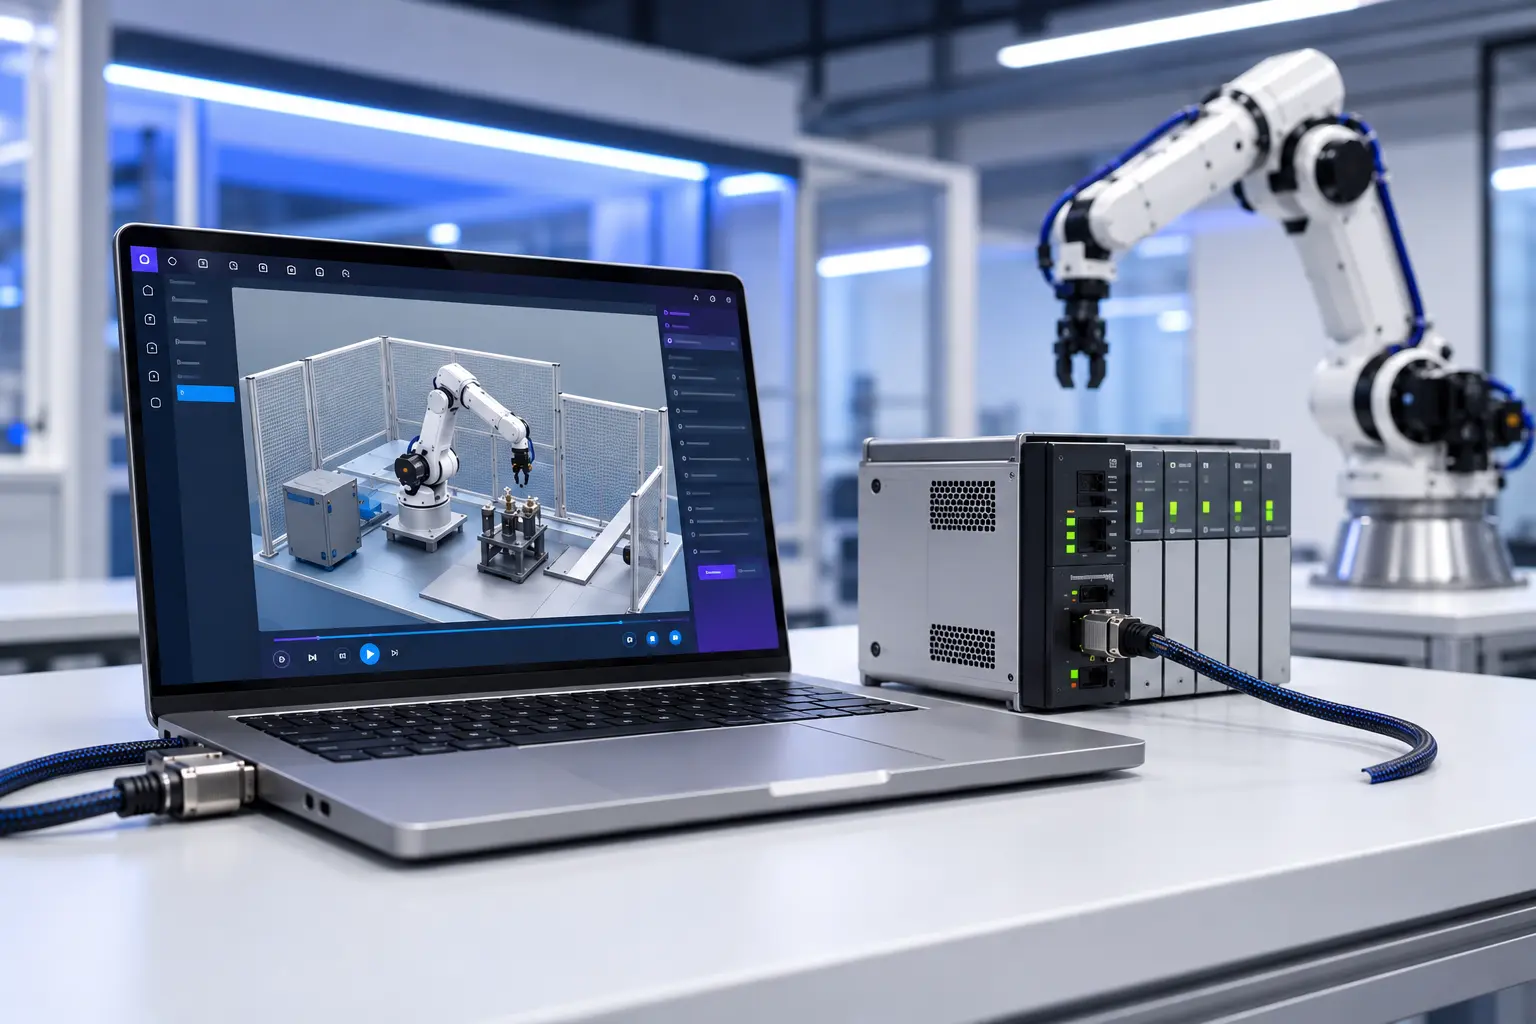
Full Software-in-the-Loop and Hardware-in-the-Loop testing environments to validate controller logic and edge cases prior to physical deployment.
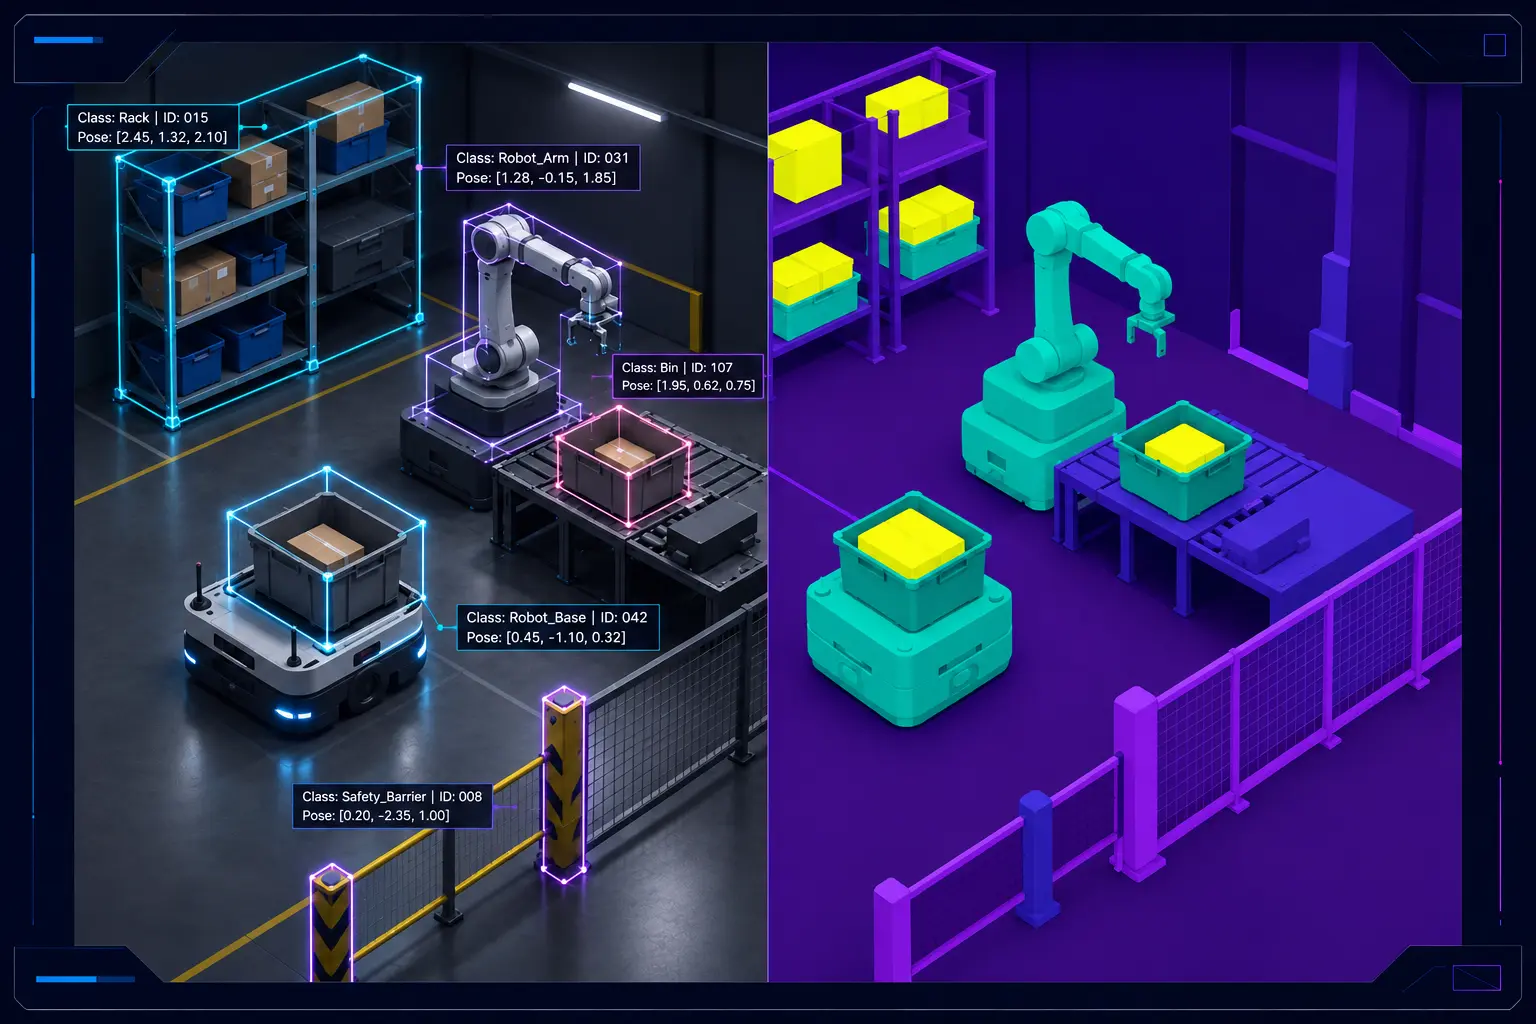
Photorealistic, automatically annotated data pipelines to train and bootstrap computer vision models without real-world data bottlenecks.
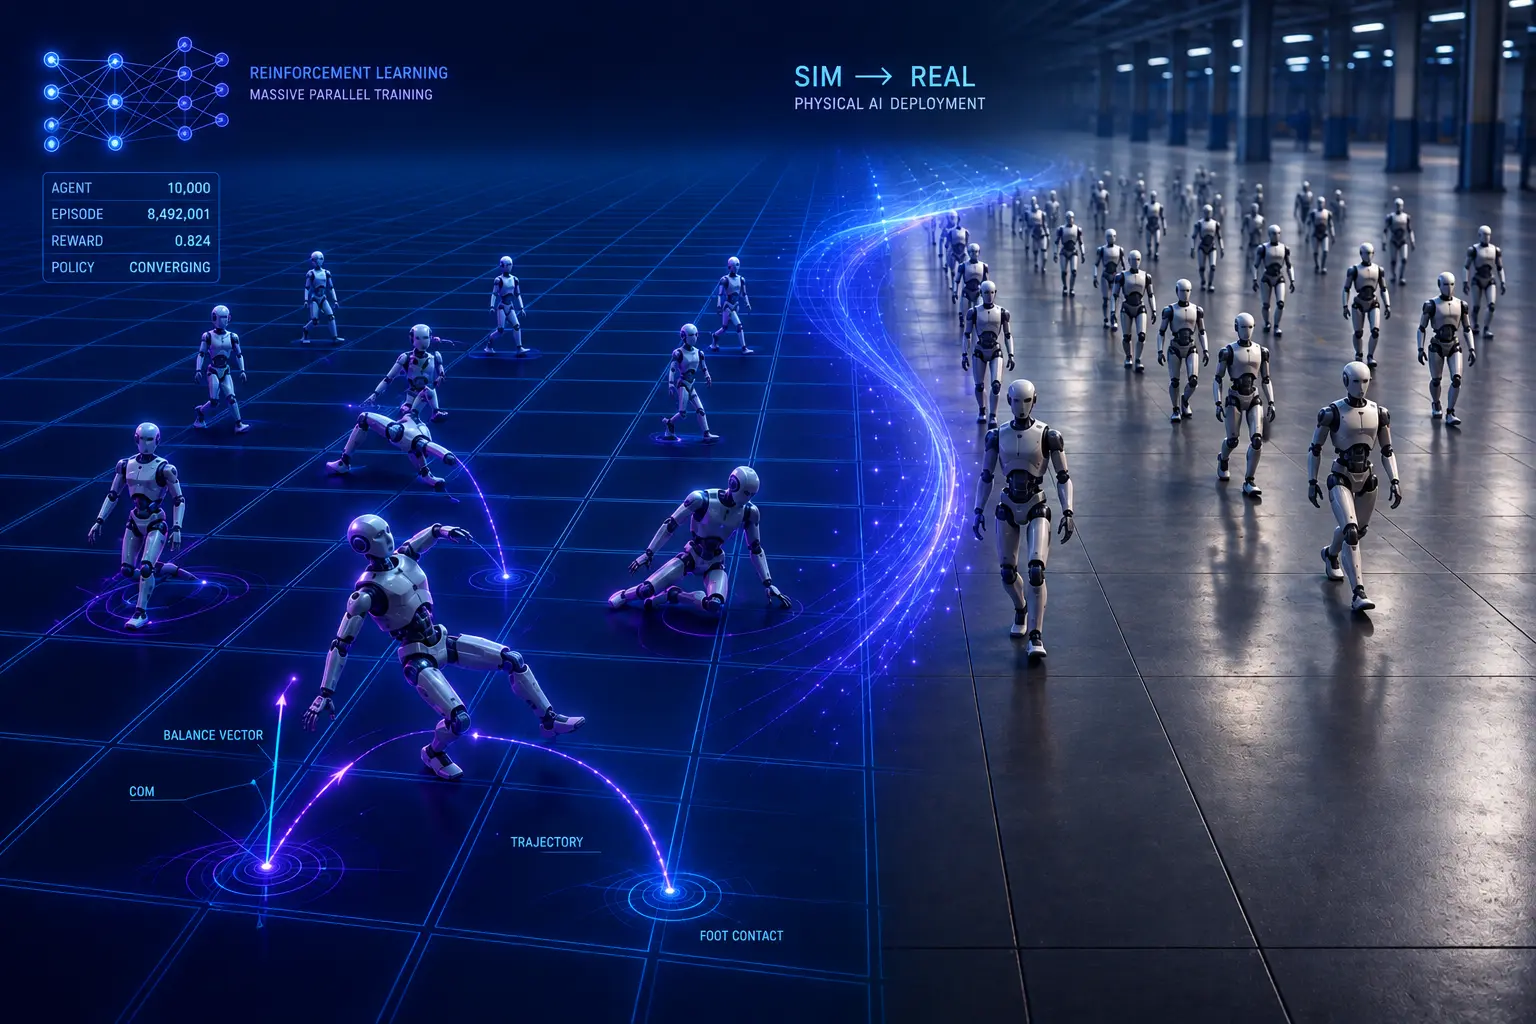
Infrastructure for training, testing, and deploying embodied AI models, from reinforcement learning to complex manipulation.
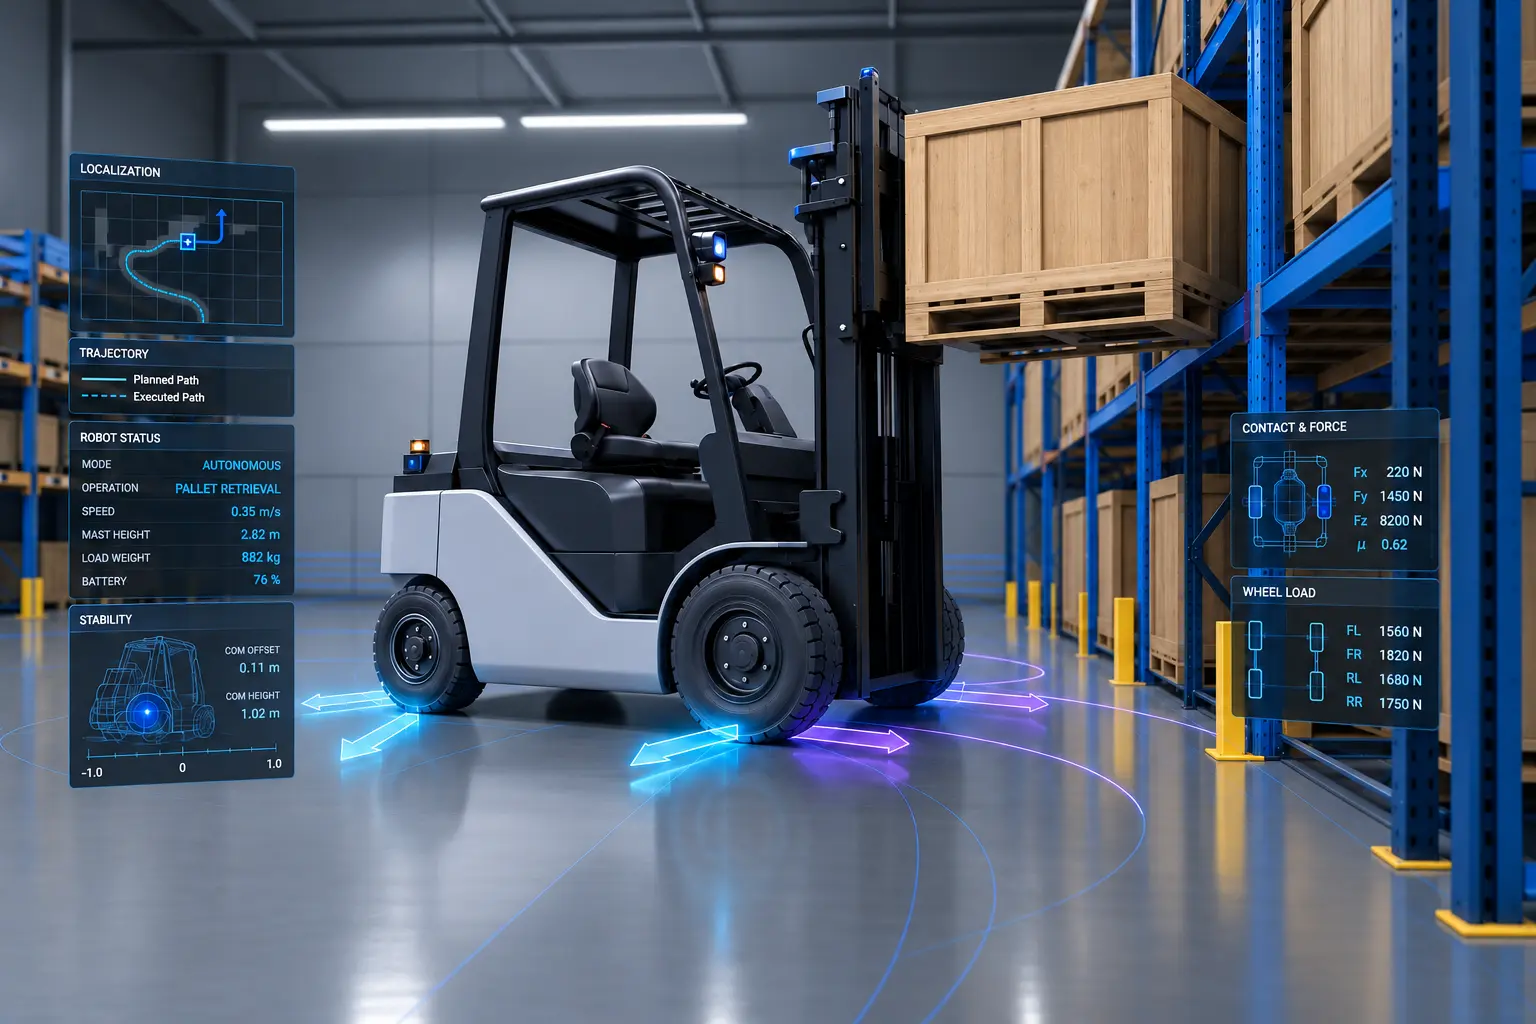
Integration of your existing controller into the simulator, supporting both ROS 2 and proprietary middleware architectures.
Full Software-in-the-Loop and Hardware-in-the-Loop testing environments to validate controller logic and edge cases prior to physical deployment.
Photorealistic, automatically annotated data pipelines to train and bootstrap computer vision models without real-world data bottlenecks.
Infrastructure for training, testing, and deploying embodied AI models, from reinforcement learning to complex manipulation.
Integration of your existing controller into the simulator, supporting both ROS 2 and proprietary middleware architectures.
Real work, anonymized by industry
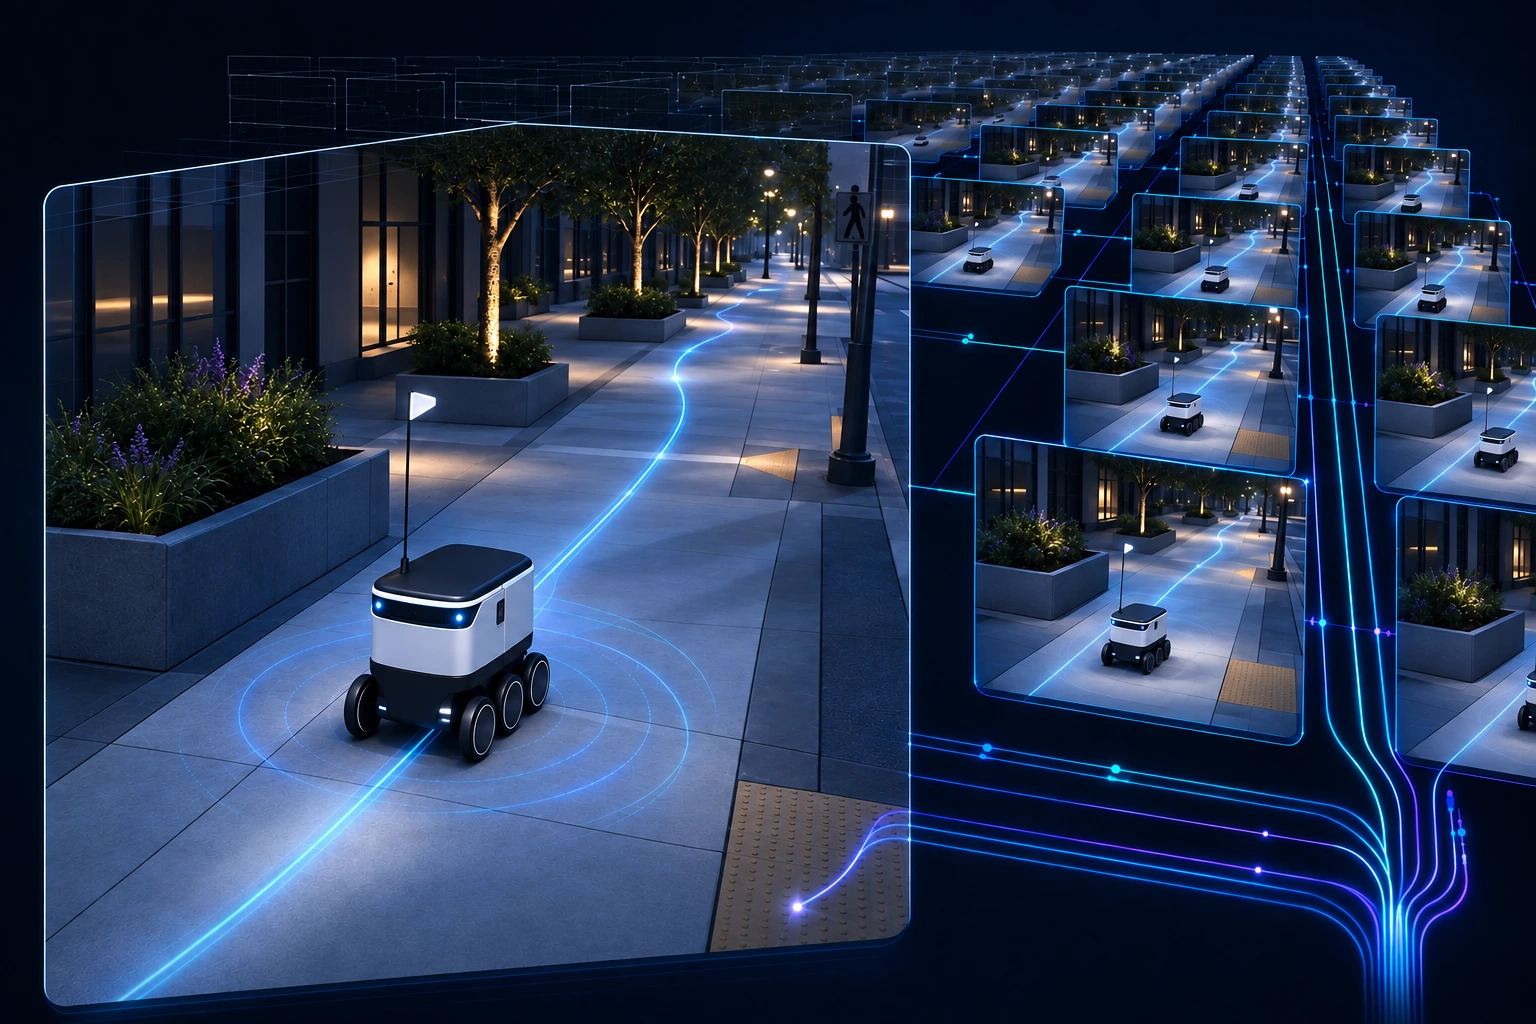
A sidewalk delivery robotics company's Isaac Sim pipeline suffered from low Real-Time Factor, causing timing sync issues with their control stack and limiting scale. We lowered memory consumption, replaced OmniGraph with direct Python scripting on physics and rendering callbacks, and moved scene manipulation to NVIDIA Fabric, eliminating latency and restoring a stable, deterministic RTF that let the client scale automated regression testing.
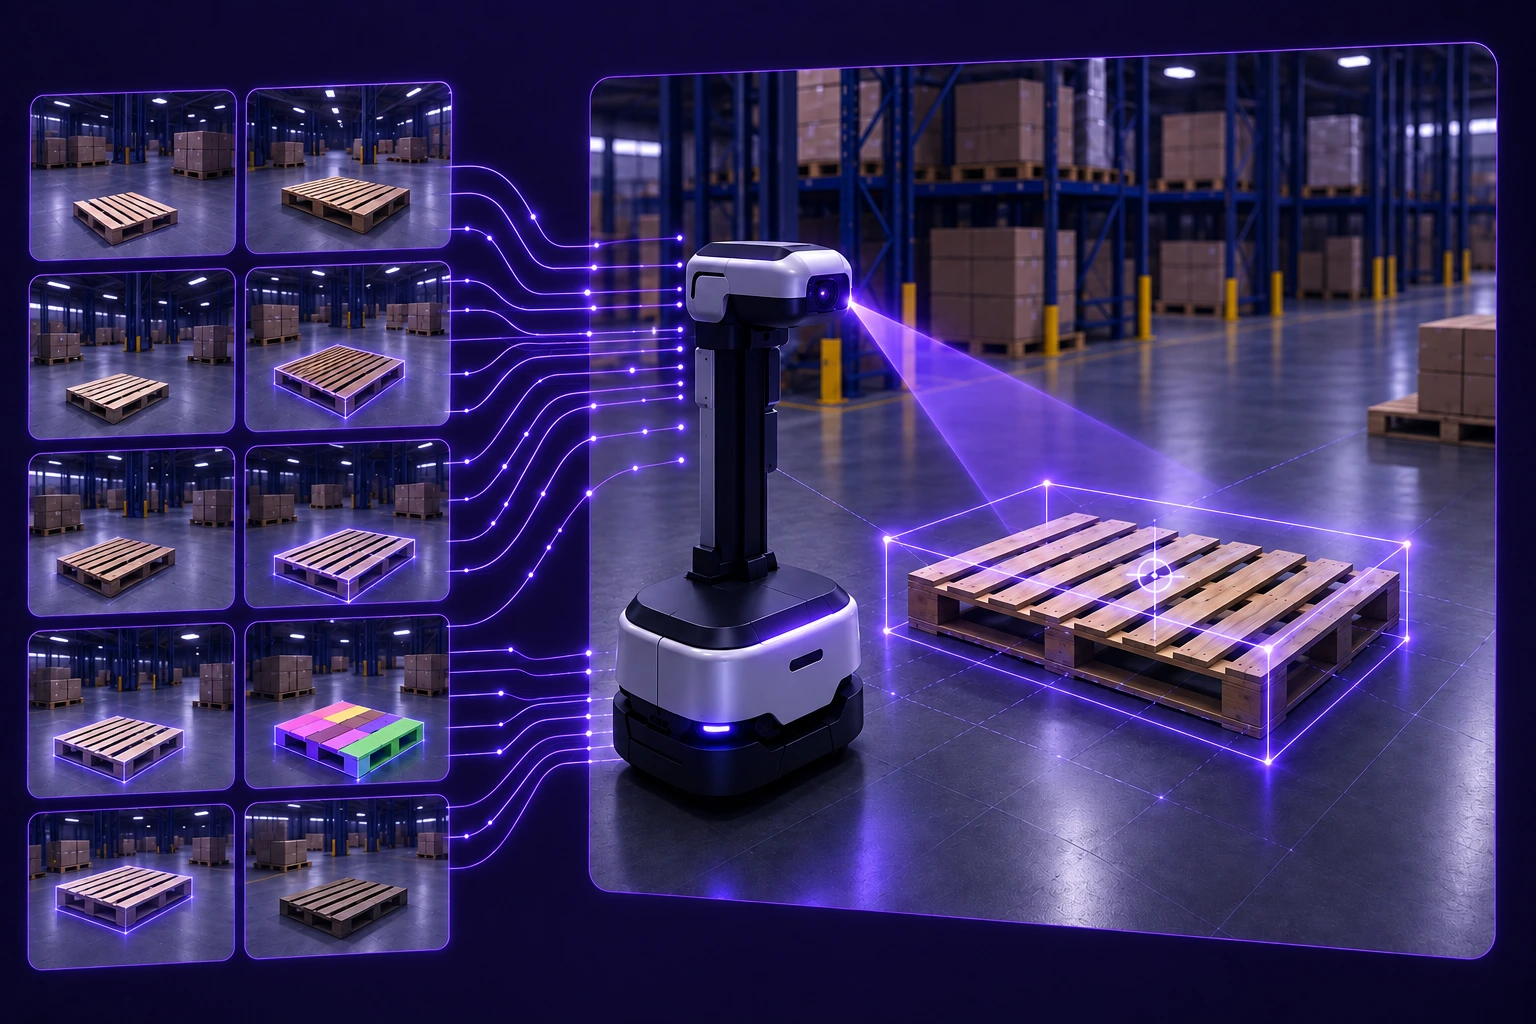
A company building hardware for intralogistics manipulation needed to precisely verify pallet model and position in the robot's line of sight, but training on real-world data alone stretched the process out over weeks. We built configurable pipelines using NVIDIA Omniverse Replicator to rapidly generate synthetic data, letting the client balance synthetic and real-world data and cut training time from weeks to just a few days.
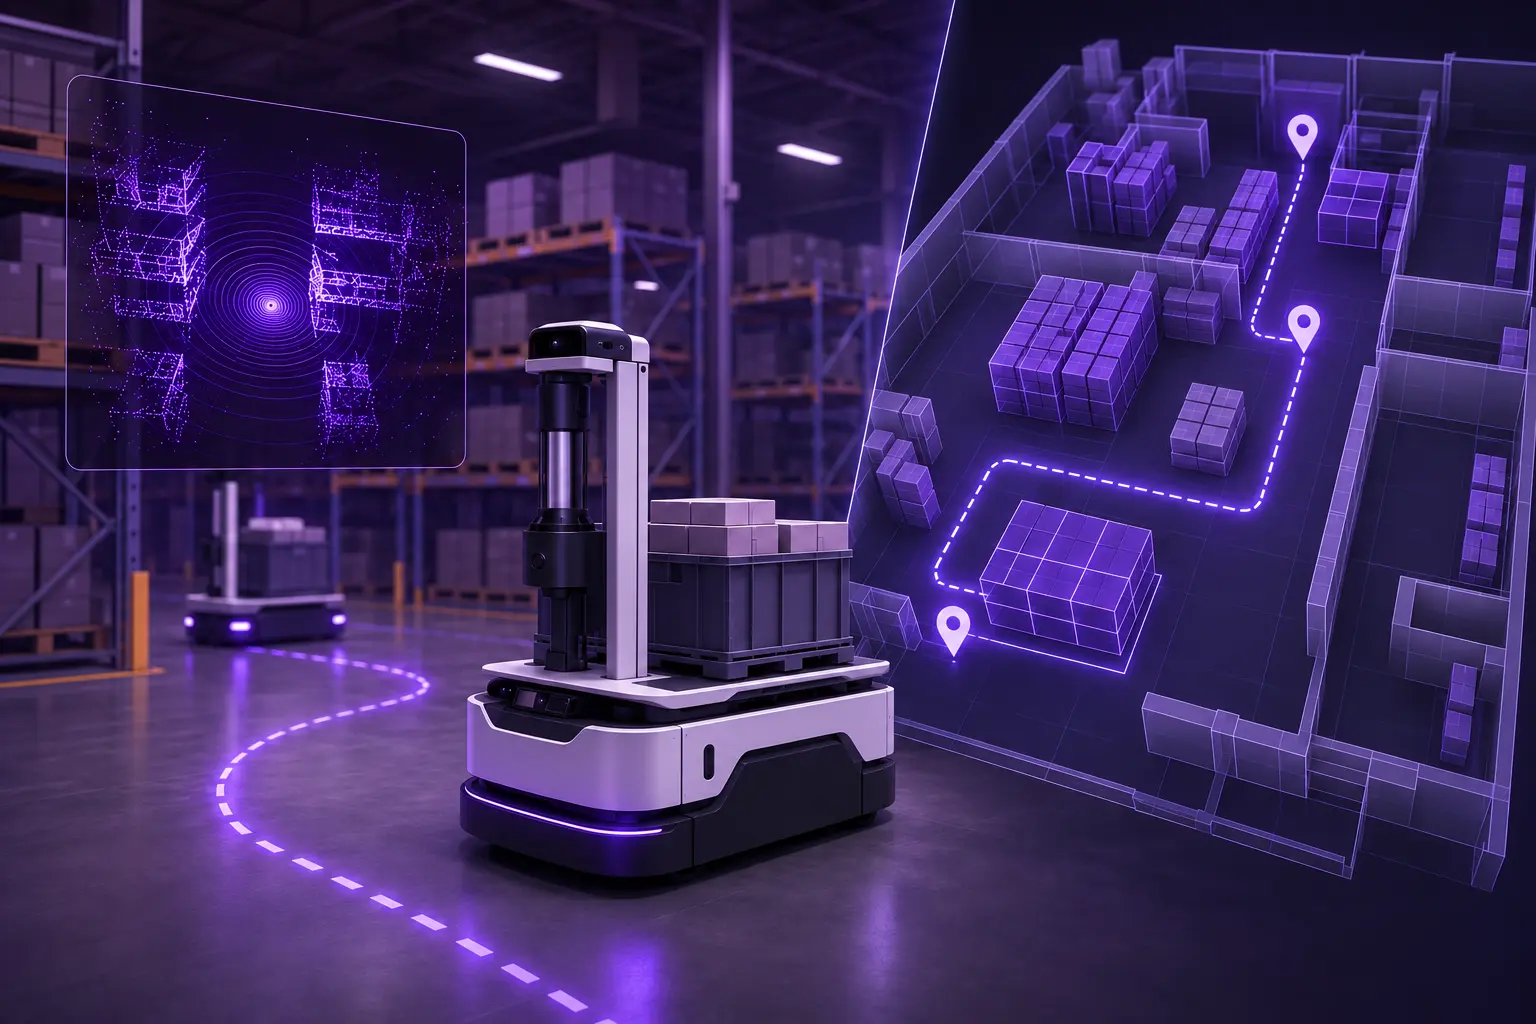
A leading AMR manufacturer needed to develop and validate navigation software before physical prototypes existed, to keep engineering on schedule and avoid hardware-software integration delays. We built a custom Gazebo Classic simulation with ROS 2 transport integration for early behavior verification. As our long-term collaboration progressed, we upgraded the infrastructure to Gazebo Harmonic to leverage LiDAR plugins and model multi-warehouse environments, enabling the client to run fleet mapping loops for new customer sites before facilities are even built.






Bring your robotics stack into NVIDIA's advanced simulation framework. We specialize in deploying high-fidelity virtual environments that streamline automated testing, accelerate AI training, and scale synthetic dataset generation.
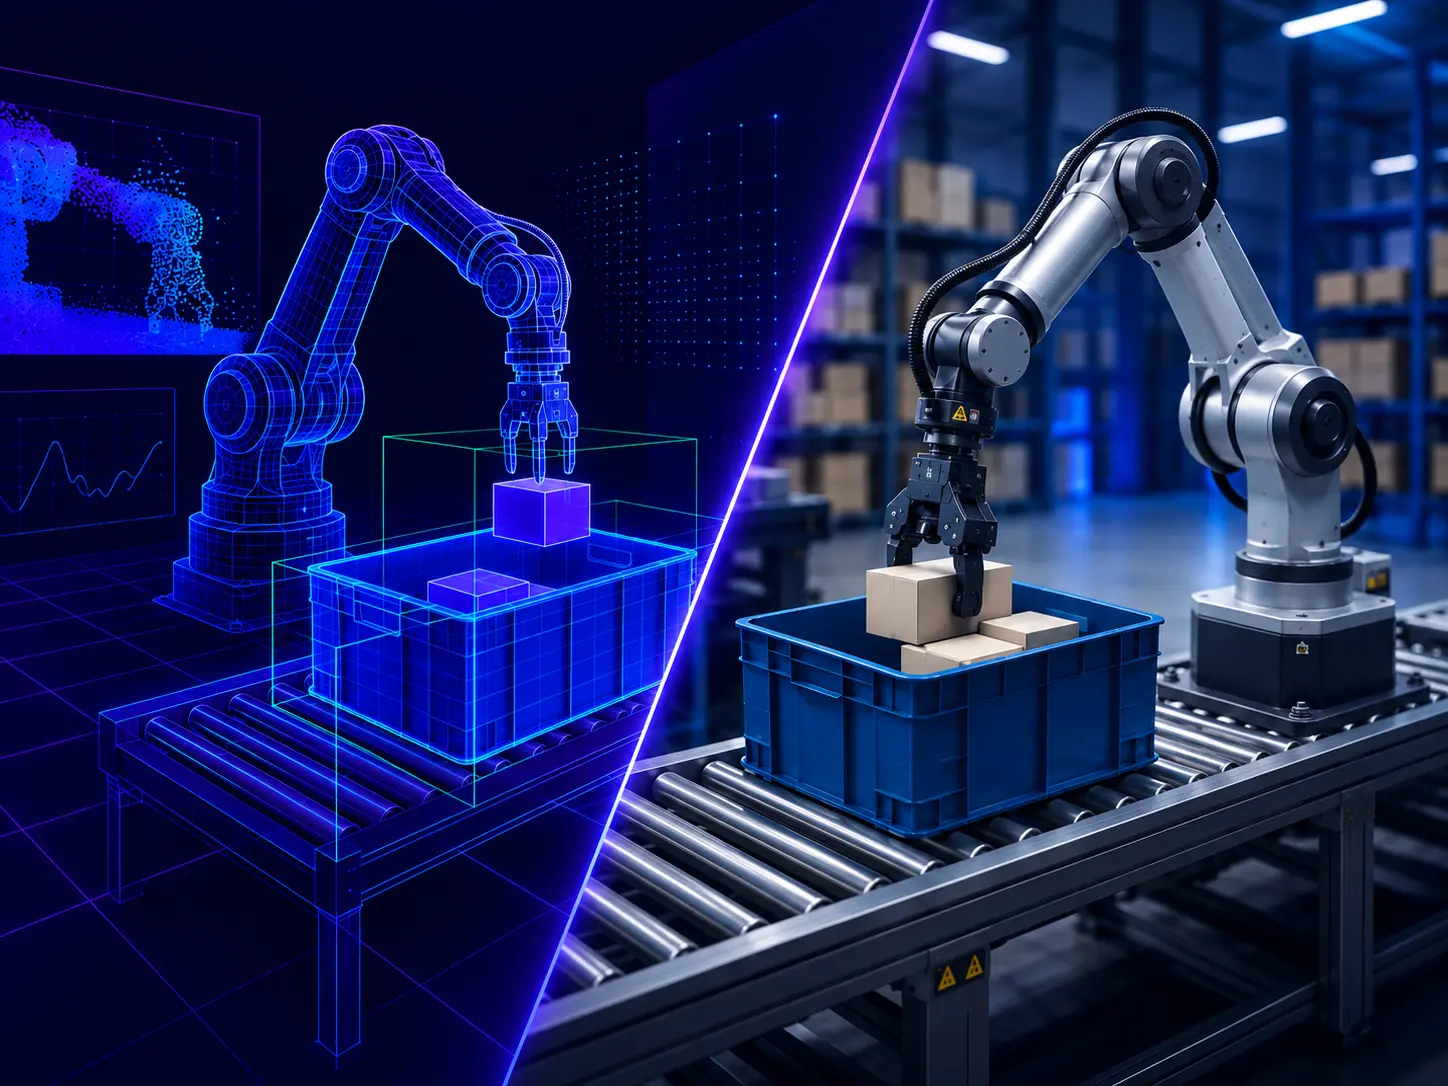
Isaac Sim pipelines covering two critical workflows: automated CI regression testing that catches edge cases before deployment, and Omniverse Replicator-powered synthetic data generation that overcomes real-world data scarcity.
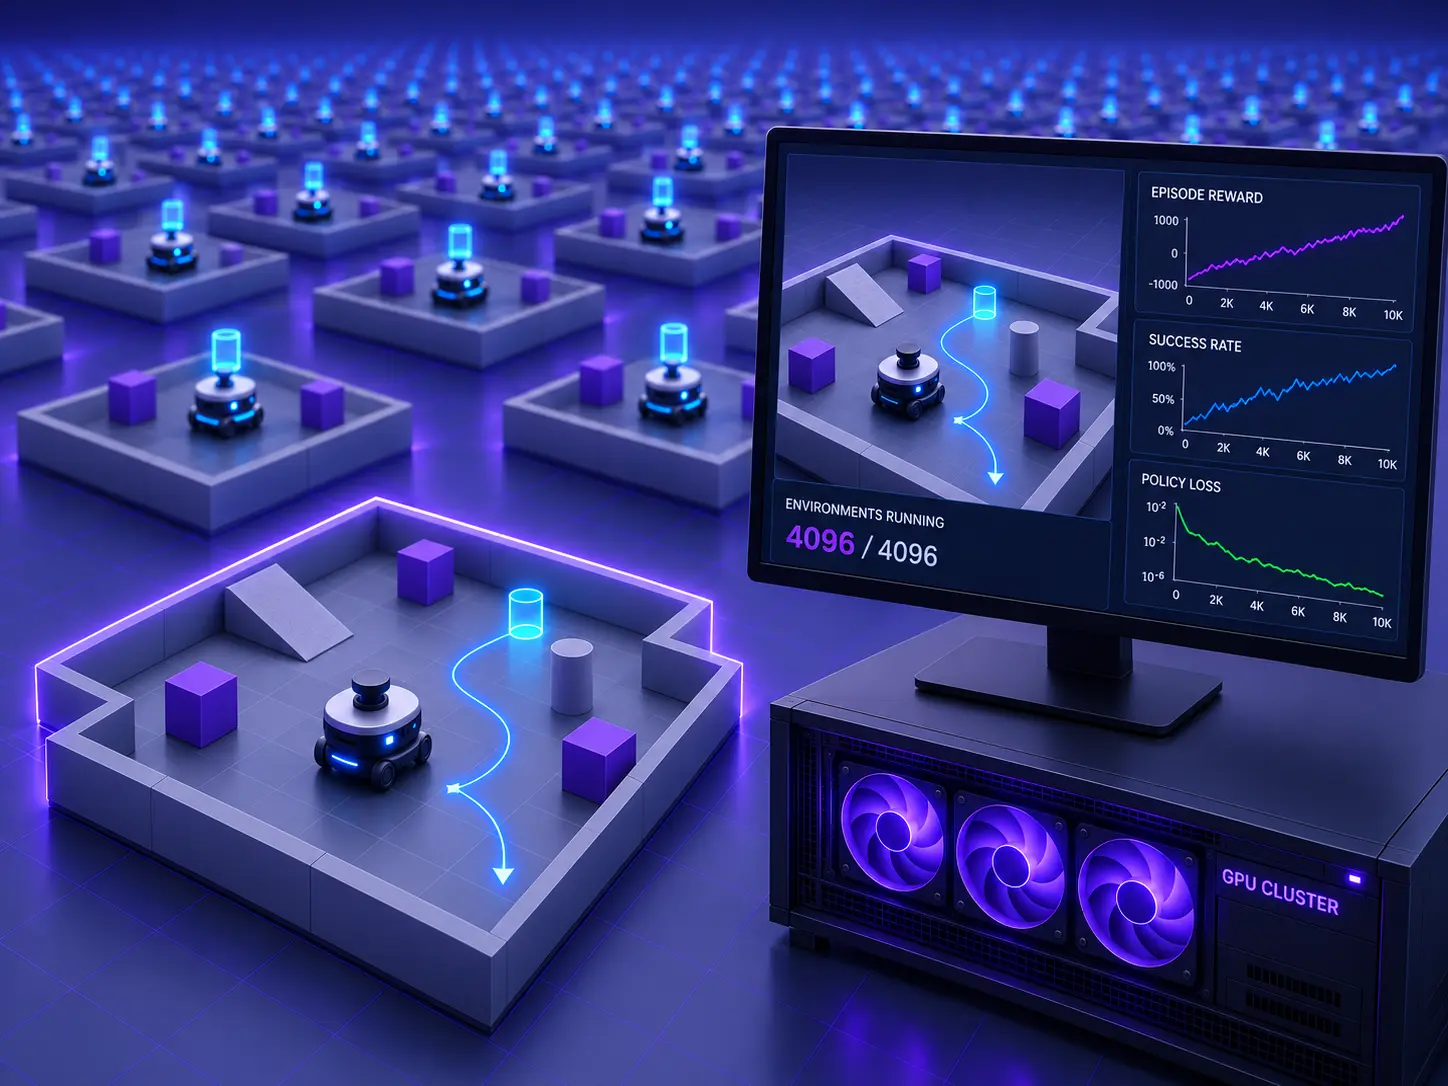
GPU-accelerated training environments utilizing Isaac Lab to optimize agent learning speeds for advanced locomotion and manipulation.
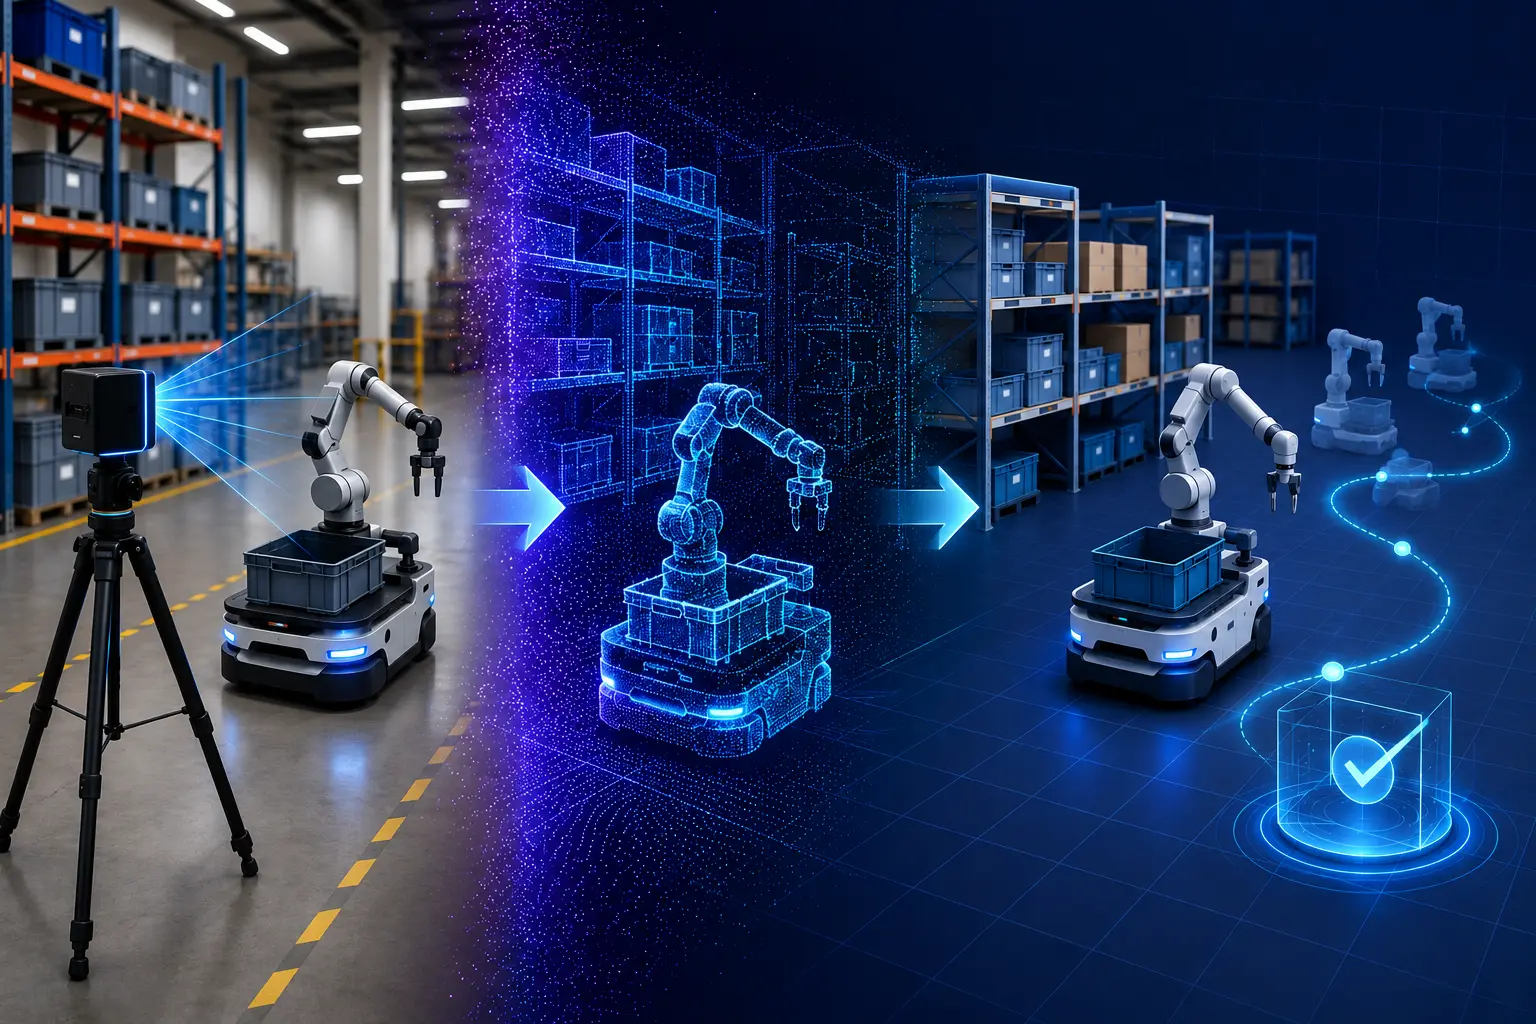
Streamlining the pipeline between physical environments and Isaac Sim. We integrate NVIDIA's neural reconstruction technology directly into your testing loops, transforming NuRec-generated scenes into functional digital twins for automated regression testing.
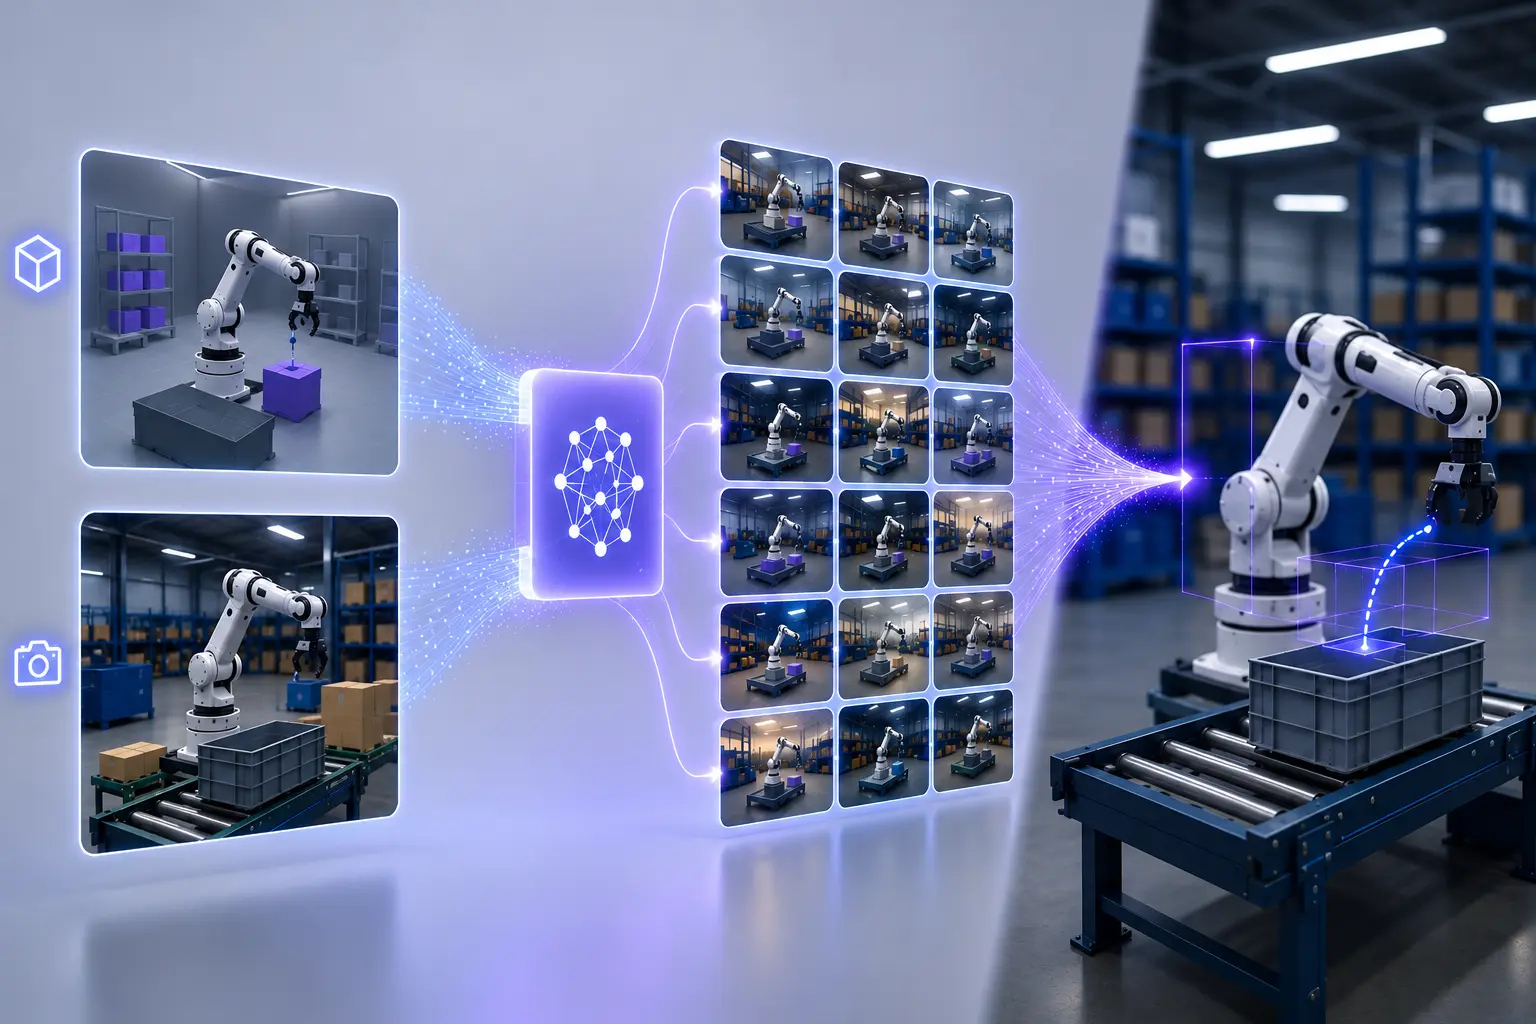
Expanding dataset variety and scaling physical AI training loops. We use NVIDIA Cosmos World Foundation Models (WFMs) to increase the variety of generated datasets, either from simulation using Omniverse Replicator or real-world data curated through the Cosmos Curator model.
Isaac Sim pipelines covering two critical workflows: automated CI regression testing that catches edge cases before deployment, and Omniverse Replicator-powered synthetic data generation that overcomes real-world data scarcity.
GPU-accelerated training environments utilizing Isaac Lab to optimize agent learning speeds for advanced locomotion and manipulation.
Streamlining the pipeline between physical environments and Isaac Sim. We integrate NVIDIA's neural reconstruction technology directly into your testing loops, transforming NuRec-generated scenes into functional digital twins for automated regression testing.
Expanding dataset variety and scaling physical AI training loops. We use NVIDIA Cosmos World Foundation Models (WFMs) to increase the variety of generated datasets, either from simulation using Omniverse Replicator or real-world data curated through the Cosmos Curator model.
Peak into our simulation work.
A step-by-step implementation of a ROS 2 and MoveIt motion planning pipeline in Isaac Sim, utilizing behavior trees to automate an AR4 robotic arm playing chess.
A step-by-step migration of an AR4 robotic arm from Gazebo to Isaac Sim, leveraging URDF conversion and Omnigraph to maintain ROS 2 and MoveIt compatibility.
An open-source deployment configuration for running the Andino differential drive robot inside a dockerized NVIDIA Isaac Sim environment with native ROS 2 integration.
Simulation showcases from our engineering team.
We leverage a wide range of technologies to deliver innovative solutions in simulation and robotics.

Practical guides on robotics, written by experts.
A collection of whitepapers on robotics, written by our engineers and available for free download.